

4.1 Capturing Data for Structure from Motion
4.1.1 Introduction to Structure from Motion
 |
Structure from Motion combines both photogrammetry and computer vision methods of analysis, aiming to reconstruct both the position of the cameras as well as the three-dimensional geometry of the captured scene/object. By analysing, therefore, the sequential change of a camera position relative to the subject in an image dataset, SfM can determine the 3D structure of the photographed subject. To determine the camera position in each photograph, SfM algorithms look at individual pixels trying to identify the same pixel in more than one photograph.
 |
|
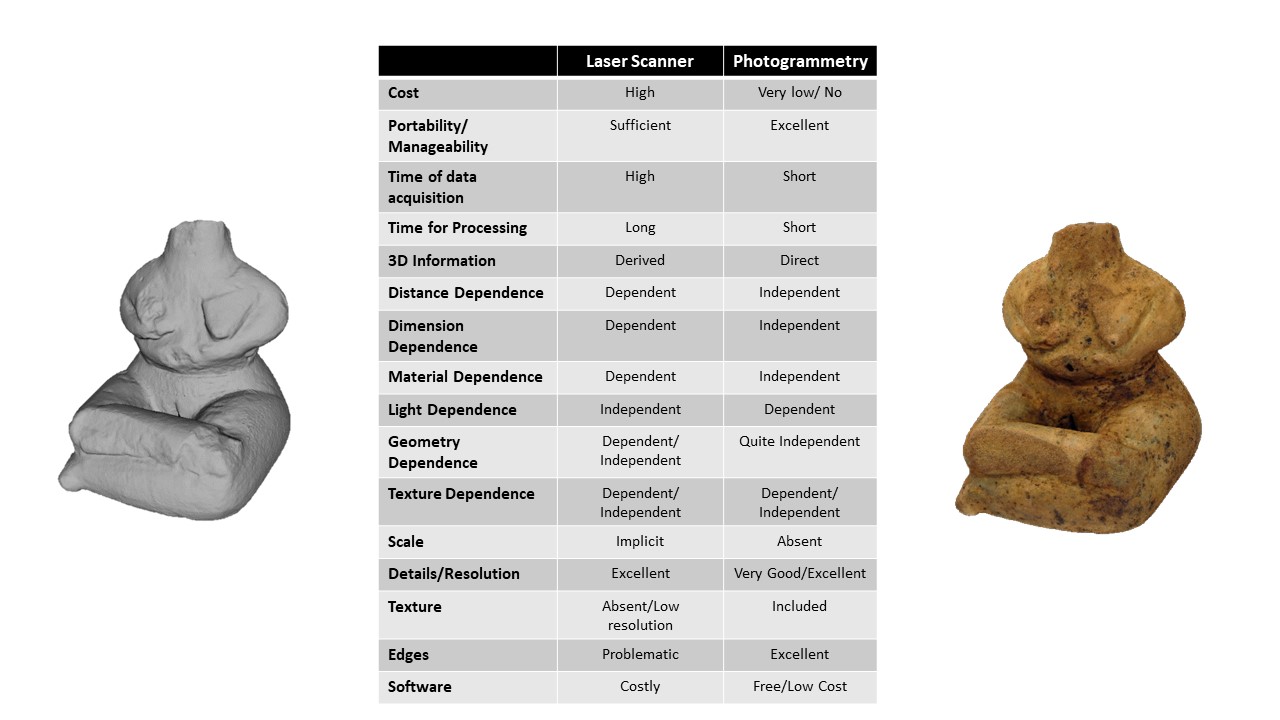
Laser Scanning vs. Photogrammetry (click to enlarge the figure) |
Recent advances in cameras, computer processors and photogrammetry/SfM software, have turned photogrammetry into a powerful technique which produces dense and accurate models, similar to those produced by non-contact 3D digitisers (laser scanners); devices that capture three-dimensional information by using laser or light projection techniques to collect points at a high rate and produce results in real time. In the image on the left, you see a comparison between laser scanner and photogrammetry/SfM applications. When it comes to the cost of the two, laser scanners cost significantly higher than a camera required for photogrammetry. Depending on the resolution that laser scanners can capture, their cost might range from a few thousand euros to over €50.000. At the same time, the processing software is often proprietary (which comes with a higher cost) and their learning curve quite steep. Quite on the contrary, photogrammetry only requires regular camera equipment and software that is either free or with relatively low cost. Although the most prominent photogrammetric software is also proprietary and increasing number of free/open source solutions can compete with the results that commercial software produces. Although the results of the two are nowadays quite comparable (centimeter or sub-centimeter accuracy) laser scanners are quite dependent on their distance from the subject, its size and material, as well as texture. On the other hand, photogrammetry is relatively independent when it comes to the distance between the camera and the object as well as their dimension. Anything that can be photographed, can work well in photogrammetry applications. Both methods have some weak points when it comes to certain materials. For example, photogrammetry cannot work in environments without light or for objects/surfaces that are shiny and highly reflective. On the other hand, laser scanners also cannot cope with reflective or black surfaces; and many laser scanners are not good in capturing textures. This is mainly because scanners are devices originally developed for engineering, in which accurate geometry (and not texture) is the most important factor. Depending on the type and size of the subjects (e.g. objects with rough edges), data acquisition via laser scanners can be very time consuming (especially with hand-held scanners) contrary to photogrammetry that would typically take a few minutes for the trained user. Similarly, processing laser scanned data (points clouds) is typically more time consuming than processing a photogrammetric dataset. Both are also dependent on the computational power of the device used for processing. Laser scanners are powerful devices that can achieve millimeter or even sub-millimeter accuracy.
Until a few years ago, there were no alternatives to laser scanning and photogrammetric/computer vision technologies were not advanced enough to provide comparable results. Both methods have strengths and weaknesses and therefore any decisions regarding the employment of one technology over the other should take into account the needs of the individual/institution and the peculiarities and future uses of the recorded subjects. Choices driven by technological fetishism and/or superficial knowledge of the strengths and exigencies of the technologies will most likely lead to poor results and implementations.
Since Structure from Motion is a universal method that can be applied to any kind of object there is a broad range of potential application areas beyond cultural heritage, including engineering surveying and civil engineering, industrial applications, medicine (Luhmann et al. 2019) and forensics (Chapman and Colwill 2019). The slideshow below presents some characteristic SfM applications, mostly focusing on cultural heritage and related fields. Scroll with your cursor in the window to see the full content.
References
- Aicardi, E., Chiabrando, F., Lingua, AM., and Noardo, F. (2018). Recent Trends in Cultural Heritage 3D Survey: The Photogrammetric Computer Vision Approach. Journal of Cultural Heritage 32: 257-266. https://doi.org/10.1016/j.culher.2017.11.006
- Baier, W., & Rando, C. (2016). Developing the use of Structure-from-Motion in mass grave documentation. Forensic science international, 261, 19-25. https://doi.org/10.1016/j.forsciint.2015.12.008
- Beale, G., & Beale, N. (2015). Community-driven approaches to open source archaeological imaging. In Edwards, B., Wilson, A. (Eds.), Open Source Archaeology: Ethics and Practice, pp. 44-63. De Gruyter Open. http://eprints.gla.ac.uk/167792/1/167792.pdf
- Historic England 2017 Photogrammetric Applications for Cultural Heritage. Guidance for Good Practice. Swindon. Historic England. https://historicengland.org.uk/images-books/publications/photogrammetric-applications-for-cultural-heritage/heag066-photogrammetric-applications-cultural-heritage/
- Howland, MD, Kuester, F., & Levy, TE. (2014). Photogrammetry in the field: Documenting, recording, and presenting archaeology. Mediterranean Archaeology and Archaeometry, 14(4), 101-108. Retrieved from https://escholarship.org/uc/item/5ps0z7pf
- Jones, S. Jeffrey, S., Maxwell, M., Hale, A. & Jones, C. (2017): 3D heritage visualisation and the negotiation of authenticity: the ACCORD project, International Journal of Heritage Studies, 24:333-353. https://doi.org/10.1080/13527258.2017.1378905
- Luhmann, T., Robson, S., Kyle, S., et al. (2019). Close-Range Photogrammetry and 3D Imaging. Berlin, Boston: De Gruyter. Retrieved 26 Dec. 2019, from https://www.degruyter.com/view/product/506249
- Miles H.C., Wilson A.T., Labrosse F., Tiddeman B., Roberts J.C. (2016) A Community-Built Virtual Heritage Collection. In: Gavrilova M., Tan C., Iglesias A., Shinya M., Galvez A., Sourin A. (eds) Transactions on Computational Science XXVI. Lecture Notes in Computer Science, vol 9550. Springer, Berlin, Heidelberg. https://doi.org/10.1007/978-3-662-49247-5_6
- Pollefeys, M. and VanGool, L. (2002). From Images to 3D Models. Communications of the ACM 45(7). 50-55. http://dx.doi.org/10.1145/514236.514263
- Remondino, F. and El-Hakim, S. (2006). Image-based 3D Modelling: A Review. The Photogrammetric Record 21(115). 269-291. https://onlinelibrary.wiley.com/doi/pdf/10.1111/j.1477-9730.2006.00383.x?casa_token=N7MxlM8aJbYAAAAA:uXwRuCssSSeE5DEnjVxK65FV-I7i-S-f1Llwn1U67CzAcskTVh-WE45_I_XOBY6_Ud82HlUd5lNe-v0v
- Remondino, F. (2011). Heritage Recording and 3D Modeling with Photogrammetry and 3D Scanning. Remote Sensing 3(6). 1104-1138. https://www.mdpi.com/2072-4292/3/6/1104/pdf
- Reu, J. (2019). Image‐Based 3D Modeling. In The Encyclopedia of Archaeological Sciences, S. L. López Varela (Ed.). http://dx.doi.org/10.1002/9781119188230.saseas0316
- Szeliski, R. (2010). Computer vision: algorithms and applications. Springer Science & Business Media. http://citeseerx.ist.psu.edu/viewdoc/download?doi=10.1.1.414.9846&rep=rep1&type=pdf
- Themistocleous, K. (2017). Model reconstruction for 3d vizualization of cultural heritage sites using open data from social media: The case study of Soli, Cyprus. Journal of Archaeological Science: Reports, 14, 774-781. https://doi.org/10.1016/j.jasrep.2016.08.045
- Wallace, C. (2017). Retrospective Photogrammetry in Greek Archaeology. Studies in Digital Heritage, 1(2), 607-626. https://doi.org/10.14434/sdh.v1i2.23251
Further Readings
- Bevan, A. et al. (2014). Computer vision, archaeological classification and China's terracotta warriors. Journal of Archaeological Science 49: 249-254. https://doi.org/10.1016/j.jas.2014.05.014
- Boehler, W., & Marbs, A. (2004). 3D scanning and photogrammetry for heritage applications: a comparison. In Proc. 12th Int. Conf. on Geoinformatics Geospatial Information Research: Bridging the Pacific and Atlantic (pp. 291–298). Sweden. http://giscience.hig.se/binjiang/geoinformatics/files/p291.pdf
- Brandolini, F.; Patrucco, G. (2019). Structure-from-Motion (SFM) Photogrammetry as a Non-Invasive Methodology to Digitalize Historical Documents: A Highly Flexible and Low-Cost Approach? Heritage, 2, 2124-2136. https://www.mdpi.com/2571-9408/2/3/128/htm
- Chapman, B. and Colwill, S. (2019) Three-Dimensional Crime Scene and Impression Reconstruction with Photogrammetry. J Forensic Res 10: 440. https://pdfs.semanticscholar.org/bdc4/15ced090197b45b8d1b41464a9c818339eca.pdf
- Chow, S.-K., & Chan, K.-L. (2009). Reconstruction of photorealistic 3D model of ceramic artefacts for interactive virtual exhibition. Journal of Cultural Heritage, 10(2), 161–173. https://doi.org/10.1016/j.culher.2008.08.011
- Hess, M., & Robson, S. (2010). 3D colour imaging for cultural heritage artefacts. International Archives of Photogrammetry, Remote Sensing and Spatial Information Sciences, Commission V Symposium, 38(5), 288–292. https://www.int-arch-photogramm-remote-sens-spatial-inf-sci.net/XXXIX-B5/103/2012/isprsarchives-XXXIX-B5-103-2012.pdf
- Kersten T.P., Lindstaedt M. (2012). Image-Based Low-Cost Systems for Automatic 3D Recording and Modelling of Archaeological Finds and Objects. In: Ioannides M., Fritsch D., Leissner J., Davies R., Remondino F., Caffo R. (eds) Progress in Cultural Heritage Preservation. EuroMed 2012. Lecture Notes in Computer Science, vol 7616. Springer, Berlin, Heidelberg. https://doi.org/10.1007/978-3-642-34234-9_1
- Lerma, J. L., Navarro, S., Cabrelles, M., & Villaverde, V. (2010). Terrestrial laser scanning and close range photogrammetry for 3D archaeological documentation: the Upper Palaeolithic Cave of Parpalló as a case study. Journal of Archaeological Science, 37(3), 499–507. https://doi.org/10.1016/j.jas.2009.10.011
- Matthews, N. A. (2008). Aerial and Close-Range Photogrammetric Technology: Providing Resource Documentation, Interpretation, and Preservation. U.S. Department of the Interior. Bureau of Land and Management. https://www.blm.gov/documents/national-office/blm-library/technical-note/aerial-and-close-range-photogrammetric
- De Reu, J., Plets, G., Verhoeven, G., De Smedt, P., Bats, M., Cherretté, B., … De Clercq, W. (2012). Towards a three-dimensional cost-effective registration of the archaeological heritage. Journal of Archaeological Science, 1–14. https://doi.org/10.1016/j.jas.2012.08.040
- Statham, N. (2018). Use of photogrammetry in video games: a historical overview. Games and Culture https://doi.org/10.1177/1555412018786415